
Insider Brief
- Researchers at the University of Arkansas System Division of Agriculture developed ChicGrasp, an imitation-learning robotic gripper designed to grasp chicken carcasses and place them onto shackle conveyors in poultry processing plants, according to a study published in Advanced Robotics Research.
- The system combines a dual-jaw gripper with a diffusion-policy imitation-learning algorithm that allows a robotic arm to learn grasping motions from human demonstrations and adapt to irregular, slippery poultry carcasses on processing lines.
- In experimental testing, ChicGrasp achieved about an 81% success rate but operated more slowly than human workers, highlighting both the potential and remaining performance gap for robotics automation in poultry processing.
A study by researchers at the University of Arkansas System Division of Agriculture found that a robotic gripper trained with imitation learning was able to handle chicken carcasses on a poultry processing line, demonstrating a potential approach for automating a task that has historically been difficult for robots. The work was supported by a $1 million grant from the U.S. Department of Agriculture National Institute of Food and Agriculture and the National Science Foundation.
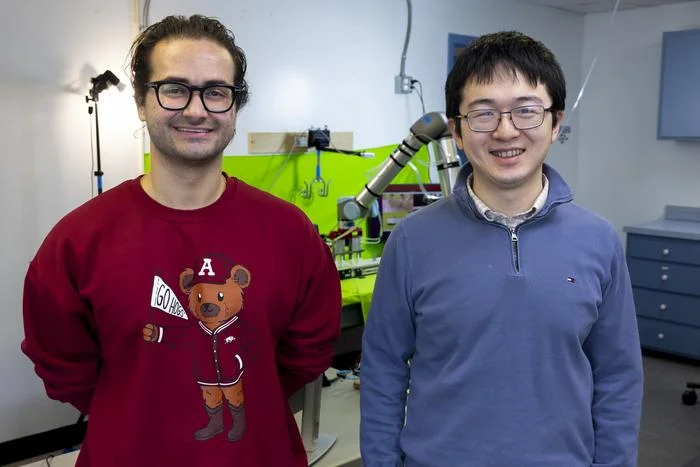
The study was led by assistant professor Dongyi Wang and graduate researcher Amirreza Davar and was published Feb. 5, 2026 in Advanced Robotics Research.
The system, called ChicGrasp, combines a dual-jaw robotic gripper with a learning framework that allows the robot to imitate human movements when grasping and hanging chickens by their legs on a shackle conveyor for processing. Researchers designed the approach to address challenges in poultry plants where carcasses vary in size and orientation and surfaces can be cold and slippery.
“It’s a physical art that has just developed in the past couple of years, which you see in things like full self-driving cars,” he said. “We are trying to do similar things using that imitation learning idea, but in chicken processing.”
According to the university, the team used an imitation-learning technique known as diffusion policy, which allows the robot to learn from recorded human demonstrations rather than relying on fixed, preprogrammed movements. Camera inputs and recorded motion trajectories were used to train the robotic arm to adapt its grasping strategy based on how each carcass appeared on the line.
“That’s why we’re getting inspired by this algorithm for the poultry industry,” Davar said. “Years ago, robots were programmed specifically to this specific coordinate at this specific time. But what if, like in the poultry industry, things are not predictable? You cannot engineer the robot to go exactly in this position. The chickens come in various sizes, and chicken legs are not always in the same position. So that’s why we wanted the robot to be able to adjust based on that specific scenario.”
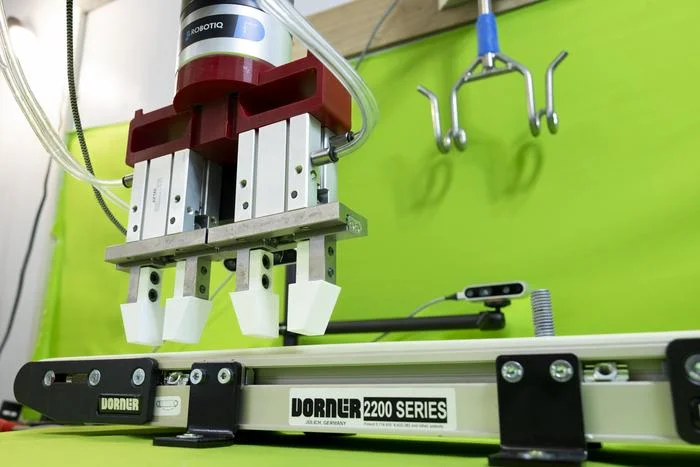
In experimental testing, the ChicGrasp system achieved a success rate of about 81% when grasping and hanging chickens, although its operating speed remained significantly slower than a human worker. The study reported a cycle time of about 38 seconds for the robotic system compared with roughly three seconds for a person performing the same task.
Researchers said closing the performance gap would likely require improvements to both the motion control system and the learning algorithms, including faster robotic arm movement and reduced idle time between operations. The prototype system cost about $59,000 to build using commercially available robotic arms and 3D-printed gripper components.
To encourage further research in agricultural robotics, the team released the system’s computer-aided design files, software code and training datasets as open source, providing a reproducible benchmark for future work in robotic manipulation of irregular biological materials.
Featured image credit: UADA photo by Paden Johnson