
Insider Brief
- X Square Robot introduced TwinDEX, a paired wearable and robotic manipulation system designed to collect robot-free training data and transfer demonstrations to real-world dexterous manipulation.
- The system uses matched three-finger nine-degree-of-freedom wearable and robotic hardware with synchronized vision wrist-position finger-state and tactile sensing to reduce the gap between data collection and deployment.
- X Square Robot reported up to 5.3 times the effective data-collection throughput of on-robot teleoperation and tested TwinDEX on tasks including tool use object manipulation and a 24-step autonomous chemistry experiment.
X Square Robot has introduced TwinDEX, a paired wearable and robotic manipulation system designed to collect training data without using a robot and transfer those demonstrations to real-world dexterous manipulation.
According to the Chinese robotics company, the system combines a wearable data-collection device with a closely matched robotic end effector with both using a three-finger, nine-degree-of-freedom design, including seven active and two passive degrees of freedom.
The company said the system is meant to addrees the training-data collection problem where robot actions depend on finger contact, force and continuous corrections as well as the position of the robot hand when they perform contact-heavy tasks such as twisting, inserting objects, pouring, opening latches and using tools.
On-robot teleoperation produces demonstrations that match the target hardware, but X Square Robot said the approach is expensive to scale because it occupies the robot, requires a prepared workspace and can depend on a skilled operator. Robot-free data collection is easier to expand, but differences between the collection device and robot can make demonstrations harder to transfer.
TwinDEX is designed to avoid those issues by matching the wearable and robotic systems across characteristics that affect policy training.
TwinDEX Specifications
- Fingers: Three
- Degrees of freedom: Nine
- Active degrees of freedom: Seven
- Passive degrees of freedom: Two
- Sensing: Multi-view RGB cameras, six-degree-of-freedom wrist poses, finger joint states and fingertip tactile signals
- Collection method: Robot-free wearable system
- Reported throughput: Up to 5.3 times on-robot teleoperation
X Square Robot said the two devices share corresponding kinematic chains, joint axes, link proportions, contact geometry, surface materials, visual appearance and sensor placement. That allows finger states measured by the wearable device to map directly to the robot’s joint space without complex hand-to-robot retargeting.
The system also synchronizes camera inputs, wrist poses, finger states and tactile signals. X Square Robot said it measures delays across sensing, model inference and execution so the timing between observations and actions during training more closely matches deployment.
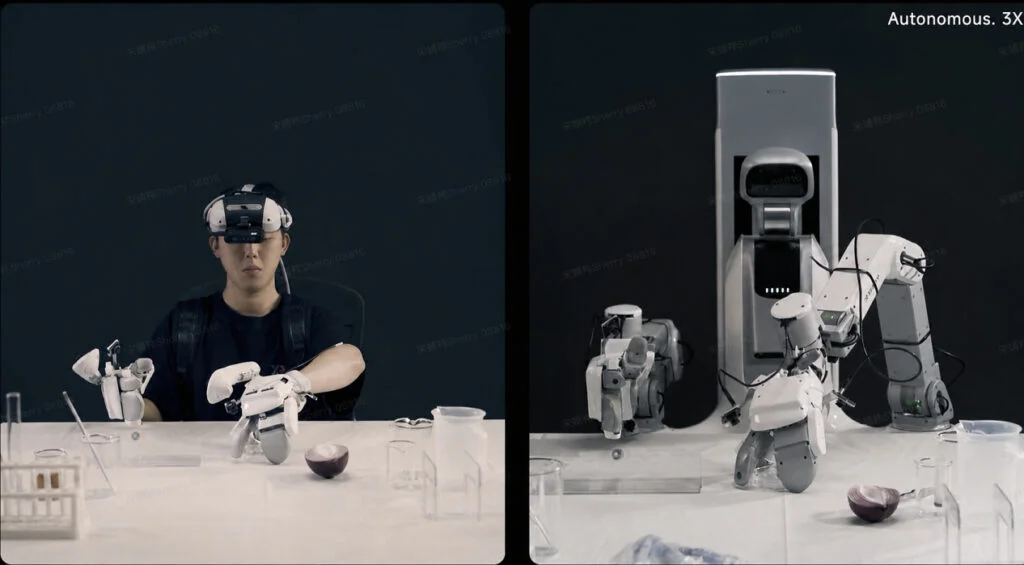
For data collection, an operator wears the exoskeleton and interacts directly with real objects without a robot. A collection unit requires one operator, a table and the wearable system, allowing multiple operators to gather demonstrations in parallel at locations including offices, kitchens and workstations.
TwinDEX Evaluation
The company evaluated TwinDEX on tasks including cap twisting, sweeping with a broom and dustpan, removing and opening a book, releasing toolbox latches and operating a syringe. X Square Robot reported up to 5.3 times the effective data-collection throughput of on-robot teleoperation.
TwinDEX was also tested on a standardized chemistry experiment completed autonomously in a single continuous run. Across 24 sub-actions, the robot handled containers, a scooper, a pipette, liquids, solids and a glass rod while switching tools and coordinating both hands.
Image credit: X Square Robot