
Insider Brief
- Eka Robotics raised $150 million in Series A funding led by Andreessen Horowitz and F-Prime at a reported $1.45 billion valuation to develop robots that combine dexterous manipulation with the speed and reliability needed for real-world deployment.
- The company is building a vision-force-action model trained with simulation and reinforcement learning to help robots use both visual and force information when handling unfamiliar objects and tasks.
- Eka claims its robots can perform up to 1,500 pick operations per hour versus a human baseline of about 600, and said the funding will support broader task capabilities and expanded customer deployments.
Eka Robotics has raised $150 million in Series A funding to build robots that can handle unfamiliar objects and tasks without giving up the speed and accuracy required for real-world work.
According to Eka, Andreessen Horowitz and F-Prime, a venture capital fund affiliated with Fidelity Investments parent FMR, led the round. Existing seed investors Obvious Ventures and E14 Fund also participated, along with MFV Partners, Bison Ventures, Glasswing Ventures, Samsung Next and several unnamed Fortune 500 strategic investors. TechCrunch reported the new funding puts eka’s valuation at $1.45 billion.
“The pathway to making general-purpose robots performant is not by mimicking human data, but by mastering physics,” the company wrote in a blog post announcing the funding. “Physics is how we and robots can reason about the world. How firmly should the robot grasp a soft raspberry?
The company is starting with dexterous manipulation, or the ability of robots to handle and interact with objects with precision. Eka said it is focusing on tasks ranging from packing delicate produce to assembling GPU server racks, where robots must adjust to different objects and physical conditions while maintaining speed and accuracy.
Vision-Force-Action
The company is developing what it calls a vision-force-action, or VFA, model that combines visual information with the physical forces generated as a robot interacts with objects. The goal is to help a robot determine not only where an object is, but how much force to apply and how to adjust its actions as conditions change.
Eka is developing the model through simulation and reinforcement learning, a method in which an AI system improves through repeated attempts and feedback. The company said simulation allows it to generate thousands of hours of robot experience in minutes by varying objects, environments and physical conditions.
Closing the Sim-to-Real Gap
A longstanding challenge with that approach has been transferring skills learned in simulation into real-world robots, particularly for tasks involving detailed physical contact. Eka said its VFA model is showing that this gap can be reduced enough to support dexterous manipulation.
The company said combining large-scale reinforcement learning with a broad range of simulated experiences allows it to pursue both speed and the ability to generalize across tasks.
“Our robots can pick a wide variety of objects outside the training distribution at a superhuman speed of 1,500 operations per hour, roughly two and a half times the human baseline of about 600 operations per hour,” the company noted. The company said the same robot can also perform tasks including screwing in a light bulb and inserting wires.
Eka said its VFA model has shown signs of transferring across different environments, objects and tasks.
What’s Next?
“This funding will help us scale our VFA model to more tasks, expanding the capabilities of our robotic systems, and accelerate customer deployments,” the company wrote. “Our focus is on transforming these capabilities into sustained, reliable performance in real operations.”
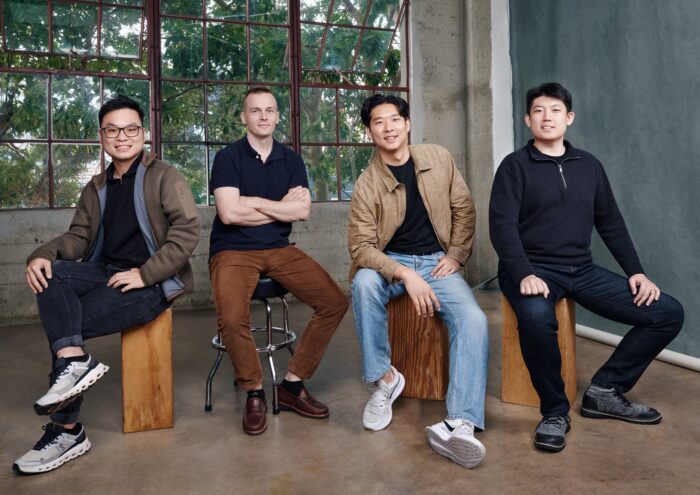
Andreesen Horowitz noted Eka’s founders bring directly relevant experience to the challenge. Pulkit Agrawal, who leads MIT CSAIL’s Improbable AI Lab, has worked on reinforcement learning, force-aware control, dexterous manipulation and transferring robot policies from simulation to the real world, while Tuomas Haarnoja co-created the Soft Actor-Critic reinforcement-learning algorithm at Berkeley and later worked at Google DeepMind training humanoid behaviors in simulation and deploying them on physical robots.
“Eka’s Vision-Force-Action model is the first approach I’ve seen that truly solves manipulation with the generality and throughput needed for deployments,” said a16z general partner Raghu Raghuram. “This team has the ideal DNA to push the frontier of robotics research while scaling commercial operations. We are absolutely thrilled to support Pulkit, Tuomas, and the exceptional team at Eka.”