Tuesday · October 20, 2026

 ·  Daily  ·  Newsletters

Resonance network: Quantum InsiderSpace Insider

Topic

Open Source

Physical AI · Humanoids

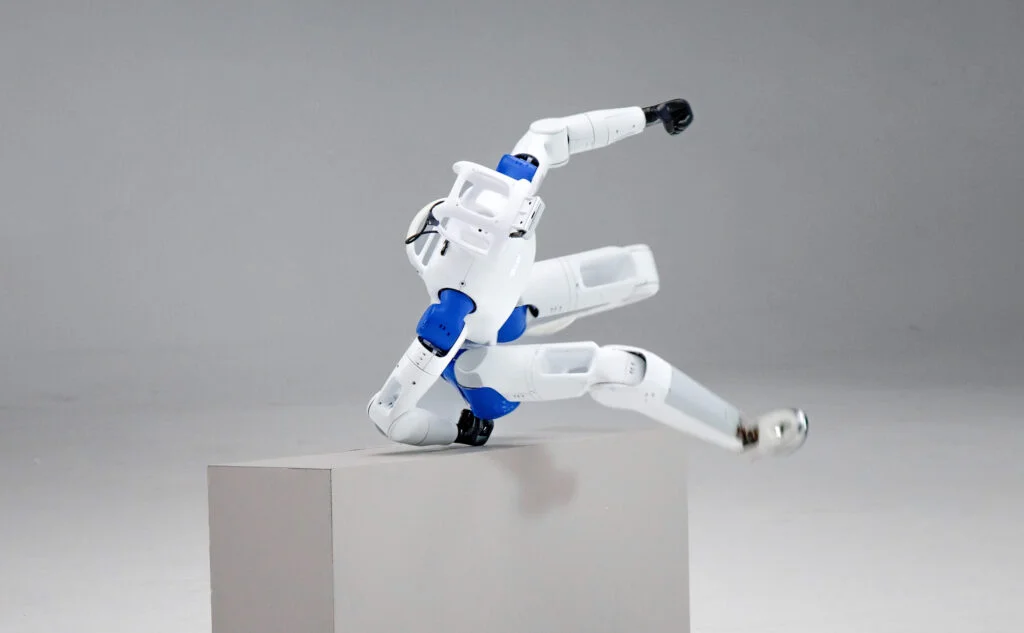
China’s RoboParty Launches Open-Source RP1 Humanoid for Robotics Research

Insider Brief RoboParty has launched RP1, a full-stack open-source humanoid robot designed for robotics research and embodied AI development, giving developers access to both the machine’s hardware and software. According to the Shanghai-based company,

5 days ago · 3 min read
Business & Markets · Enterprise

Qualcomm to Acquire PickNik, Bringing MoveIt Robotics Software Closer to Dragonwing

24 Sep 2026
Technology & Infrastructure · Applications & agents

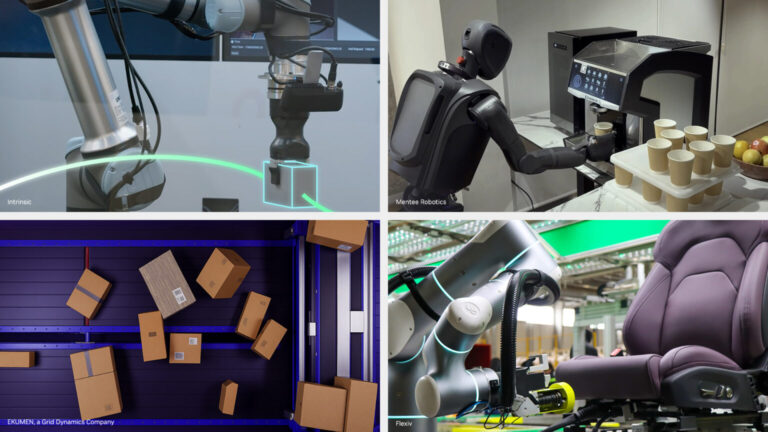
Nvidia Releases Isaac ROS 5.0 With New AI Agent Tools for Robotics Developers

23 Sep 2026
Physical AI

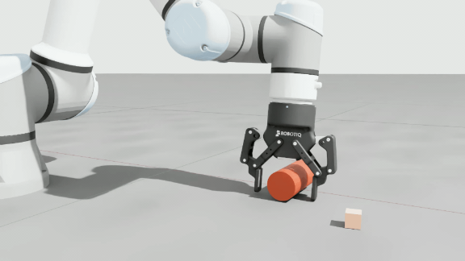
Robotiq Open-Sources New Software Tools for Adaptive Grippers

23 Sep 2026
Physical AI

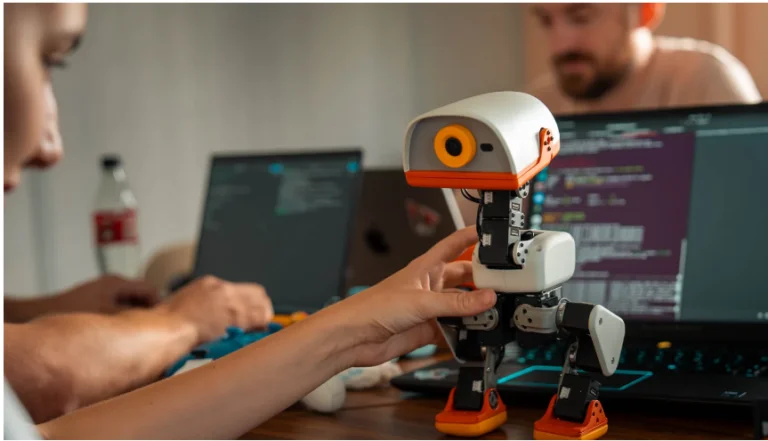
Hugging Face’s Pollen Robotics Releases Small, Cute & Open-Source ‘Microduck’ Robot

28 Aug 2026
Physical AI

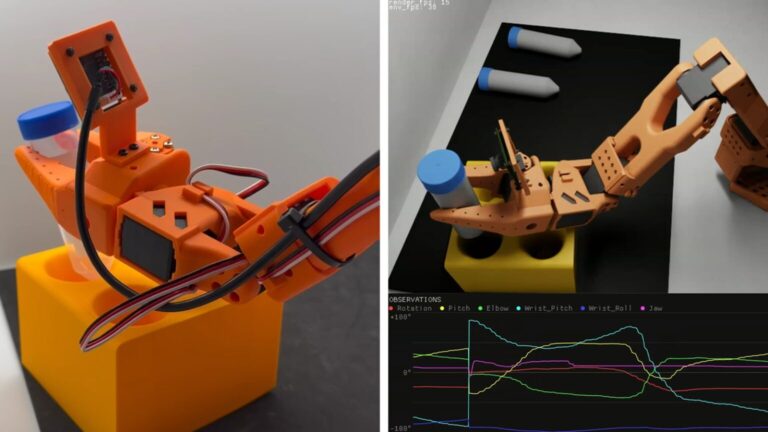
Nvidia and Hugging Face Bring New Models and Frameworks to LeRobot for Open Source Robotics

7 Jul 2026
Physical AI

Hello Robot Unveils Open-source Robot Platform Called Stretch 4

13 May 2026

Trending today

teal LED panel
Policy & Government · AI Safety

AI Risk Management in Finance: Key Lessons From the FSB’s New Report on Responsible AI

Physical AI · Humanoids

China’s Collaborative Robot Maker Fairino Raises Nearly $150M in Total After C+ & D Funding Rounds

Business & Markets · Enterprise

Anthropic and Nscale Reportedly Near Second $45B AI Compute Deal

Business & Markets · Startups

Dream Labs Raises $90M in Seed Funding to Build Foundation Models for Any Robot

Technology & Infrastructure · Models & LLMs

AWS Takes Aim at Nvidia’s PyTorch Advantage While Nvidia Expands Open-Weight Nemotron Models for Agents

The AI economy, every weekday morning

The daily briefing on LinkedIn. Free, one tap to follow.

The AI economy, every weekday morning

The daily briefing plus the weekly Scale-ups to watch edition. Free, no spam, unsubscribe any time.