
Insider Brief
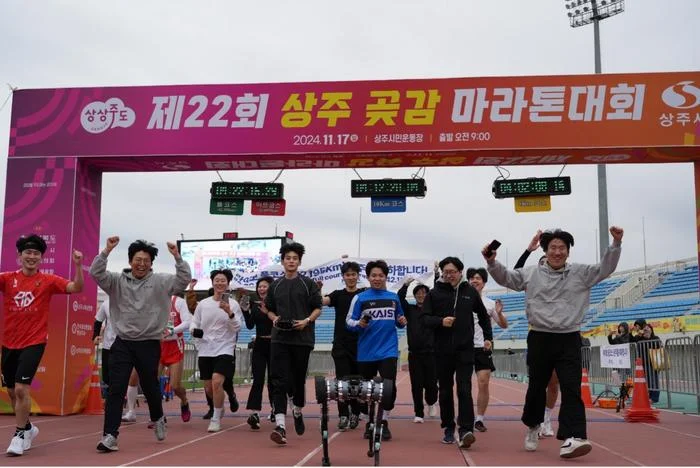
- KAIST researchers developed the quadruped robot RAIBO2 to complete a 42.195-kilometer marathon on a single battery charge, finishing the Sangju Dried Persimmon Marathon in 4 hours, 19 minutes and 52 seconds while collecting real-world energy, thermal and locomotion data.
- The team treated endurance as a whole-system engineering problem, jointly optimizing RAIBO2’s mechanical and electrical systems, actuators, motor drivers and locomotion control to reduce energy consumption while maintaining performance.
- The work was published in Nature, while KAIST faculty startup Raion Robotics is working to translate the research platform into commercial quadruped robots capable of reliably operating for extended periods in industrial environments.
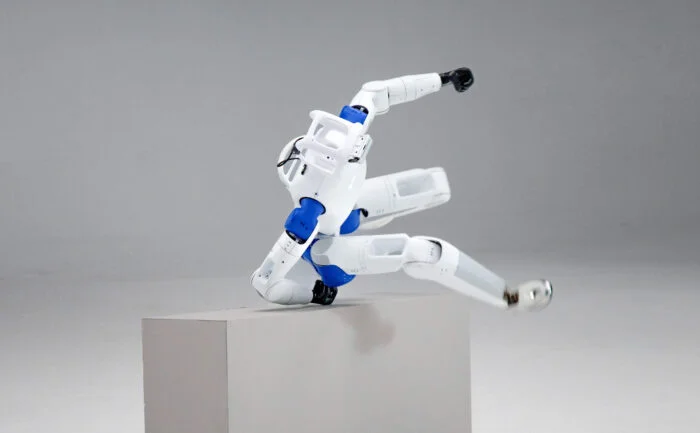
A quadruped robot developed at the Korea Advanced Institute of Science and Technology completed a full 42.195-kilometer marathon without a battery swap, giving researchers more than four hours of real-world data on energy use, thermal performance and locomotion.
According to KAIST, researchers have now detailed the RAIBO2 robot’s design and marathon performance in November 2024 at the Sangju Dried Persimmon Marathon. The robot finished thee race in 4 hours, 19 minutes and 52 seconds.
The work, published in Nature this week, was led by Professor Jemin Hwang of KAIST’s Department of Mechanical Engineering, and focused on maintaining locomotion performance while using enough energy efficiently to operate for extended periods. Choongin Lee, Donghoon Youm and Jeongsoo Park of KAIST’s Department of Mechanical Engineering were co-first authors.
“This study goes beyond demonstrating how far a quadruped robot can run,” noted Hwang. “Using actual marathon data, we demonstrated how the entire robot must be designed to achieve both high locomotion performance and energy efficiency. We will connect the world-class performance achieved in the laboratory to products that anyone can use reliably in industrial environments.”
Designing for Endurance
Rather than optimizing the battery, motors or another component independently, the researchers treated endurance as a whole-system engineering problem spanning the robot’s mechanical structure, electrical systems, actuators and locomotion control.
Researchers pointed out that quadruped robots lose energy through their actuators, electrical systems and mechanical components as their legs repeatedly move. The KAIST team analyzed those losses across RAIBO2 and jointly designed the systems to reduce energy consumption without sacrificing locomotion performance.
The approach included:
- Mechanical and electrical systems designed around energy efficiency.
- Actuation and locomotion control optimized as part of the overall system.
- Motor drivers developed by the team to provide precise control of the robot’s motors.
- Battery, thermal and actuator performance considered together rather than as separate engineering problems.
The researchers then tested the design outside the laboratory by entering RAIBO2 in an actual marathon.
More Than Four Hours of Real-World Data
RAIBO2 was officially registered for the marathon, providing formal split times along the course and researchers ran alongside it and recorded the entire run from start to finish. During the race, researchers continuously recorded RAIBO2’s internal voltage, current, temperature and battery status. Those measurements were synchronized with GPS data tracking the robot’s position, speed and altitude.
The resulting dataset allowed the team to examine how the robot maintained its performance and energy efficiency over more than four hours rather than relying on short laboratory tests or calculated estimates of maximum range, according to KAIST.
Moving From Research Robot to Product
The next challenge is translating RAIBO2’s performance into quadruped robots that can be manufactured and repeatedly operated in industrial environments. RAIBO2 was built by hand as a research platform, while commercial systems would need to reproduce its performance across multiple units at lower production costs. They would also need to meet industrial requirements for water and dust resistance, operation across a wide range of temperatures, shock and vibration durability, and electromagnetic interference and compatibility.
Raion Robotics, a KAIST faculty startup originating from Hwang’s laboratory, is working to commercialize the technology. The company contributed manufacturing technology to RAIBO2 and is developing production methods for quadruped robots designed for extended operation in real-world environments.
The KAIST team and Raion Robotics developed the robot’s mechanical and electrical systems, software, AI and motor drivers, allowing the researchers to optimize the platform as an integrated system.
Image credit: KAIST